What you get.
Segal Robotics
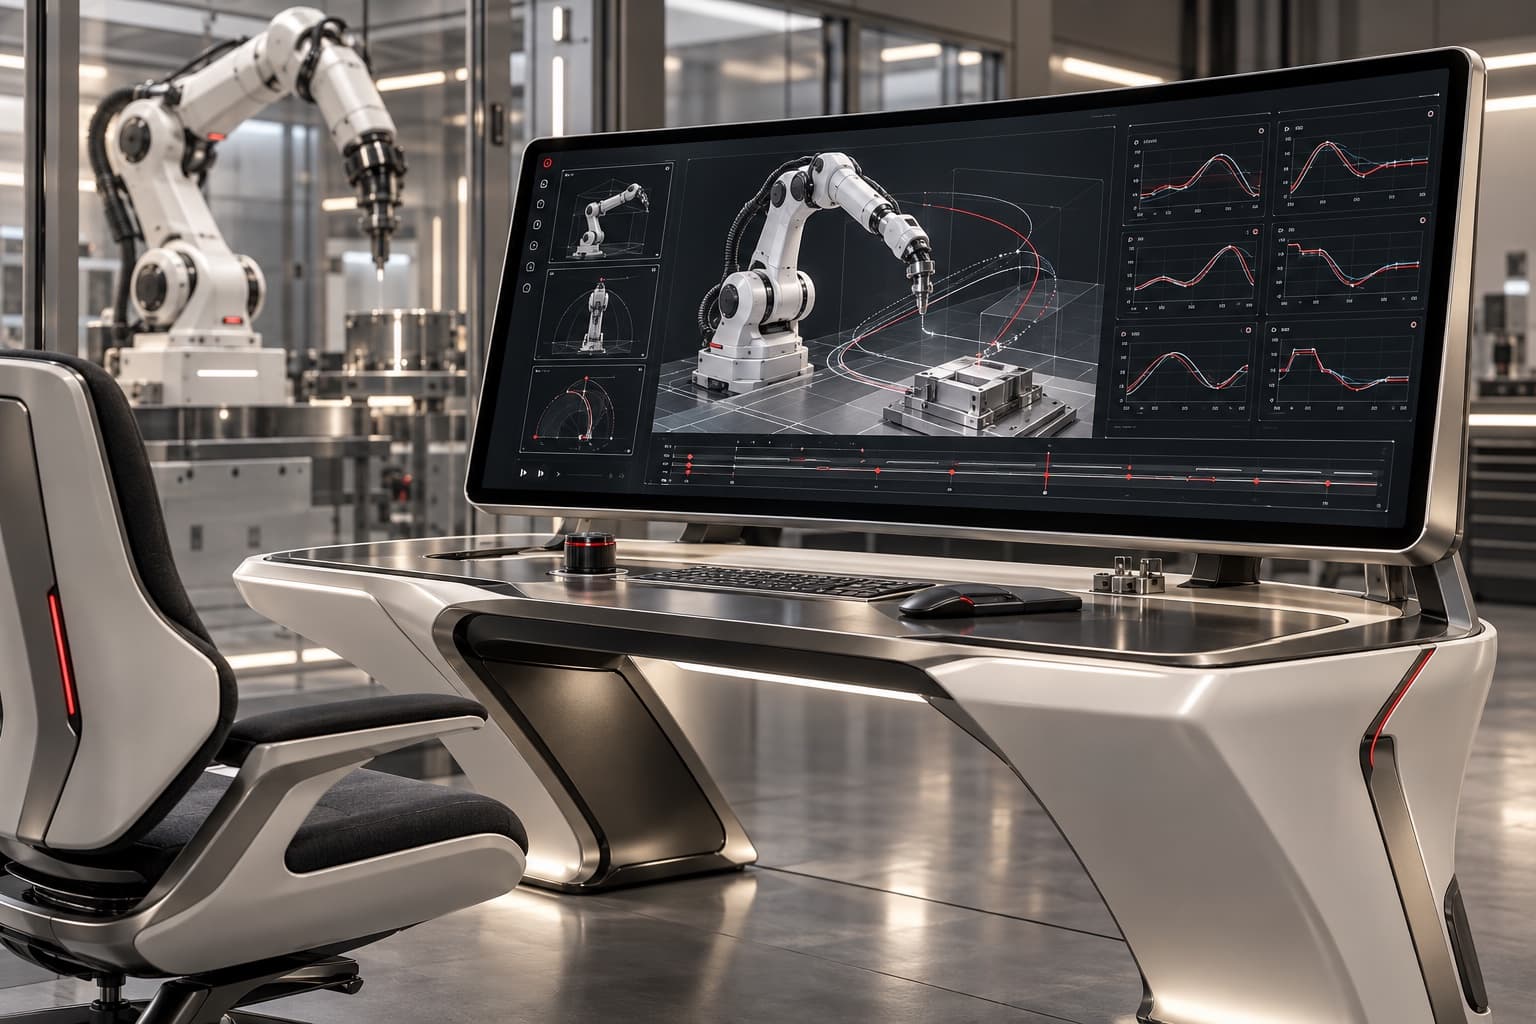
The runtime takes a path and a supervisor's command and turns them into local motion the drives can execute.
A trajectory becomes real through coordinated control of the machine's axes. Timing, limits, feedback, supervision, and recovery must remain connected to the physical system. The runtime defines how a requested movement is executed and how the machine responds when that movement cannot continue.
Local control
Time-critical functions follow the machine.
Faults
Limits, sensor faults, and a lost link have a defined response.
Integration
The same interfaces serve the component and the machine.
Stack
From the joint up to the machine.
- Operator
- Earthwork
- Motion runtime
- Perception
- Force and torque
- Servo drives
- Integrated actuators
In Robotics
05 / 11
Build the frontier
with us.
Share the objective, the requirements, and the business you want to reach. Project and partnership enquiries all come through the same form.
Discuss a Project