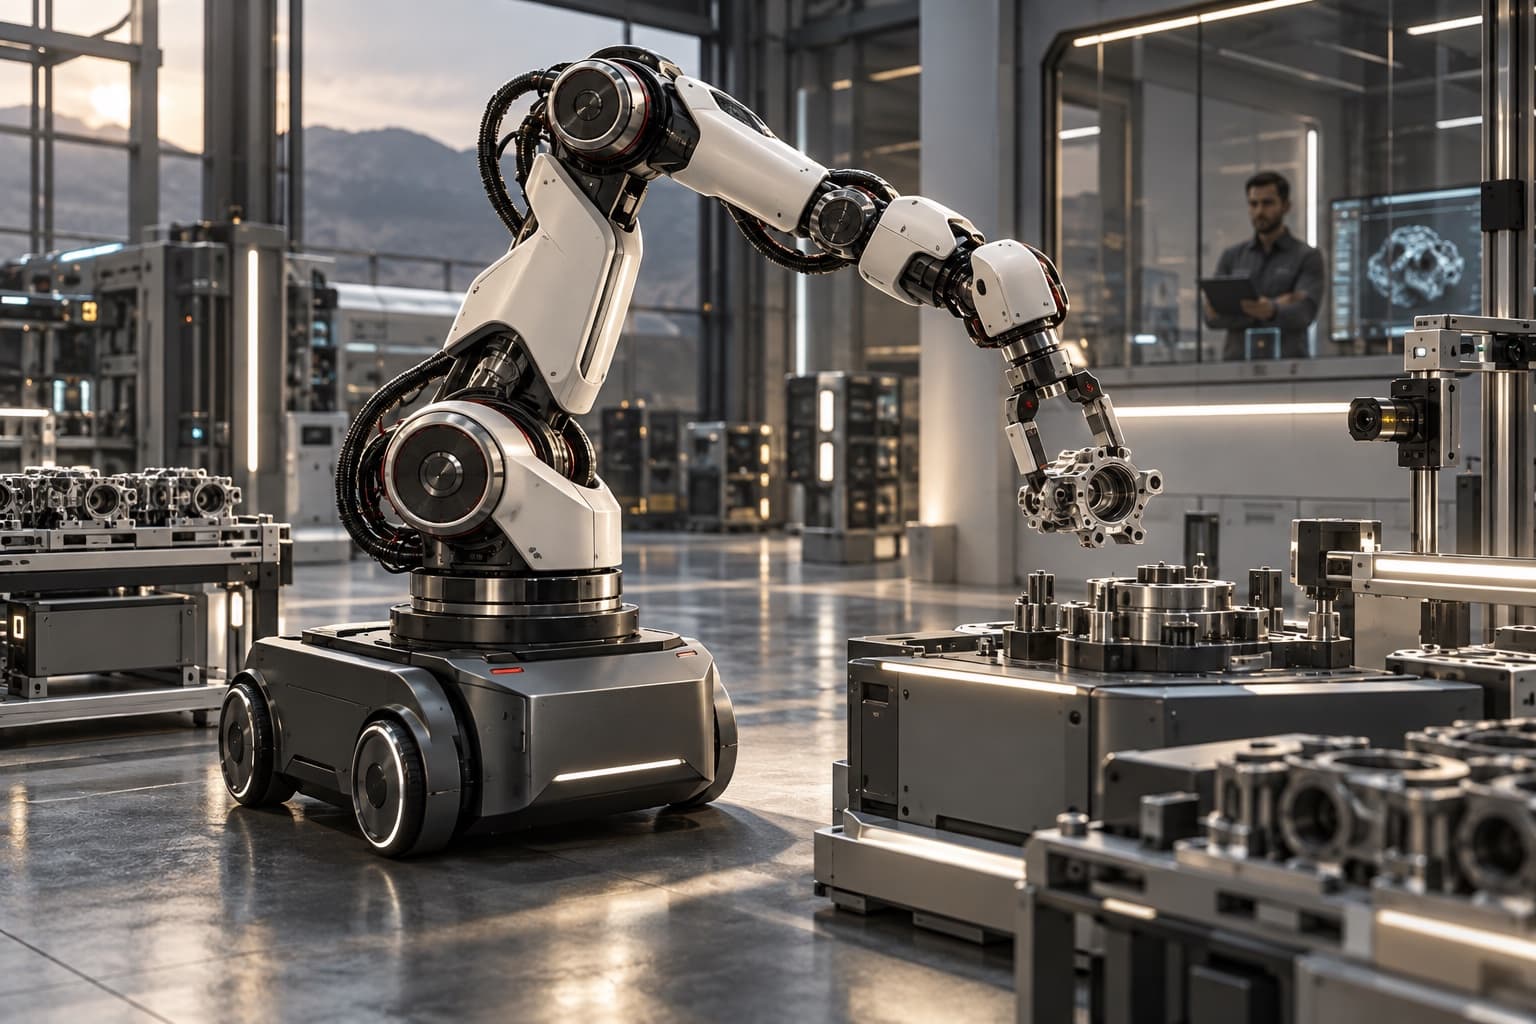
Motion is
a component.
Segal Robotics
Actuation, sensing, and control for the complete machine.
Segal Robotics builds the joint, the drive, and the sensor so the machine does the work in front of it.
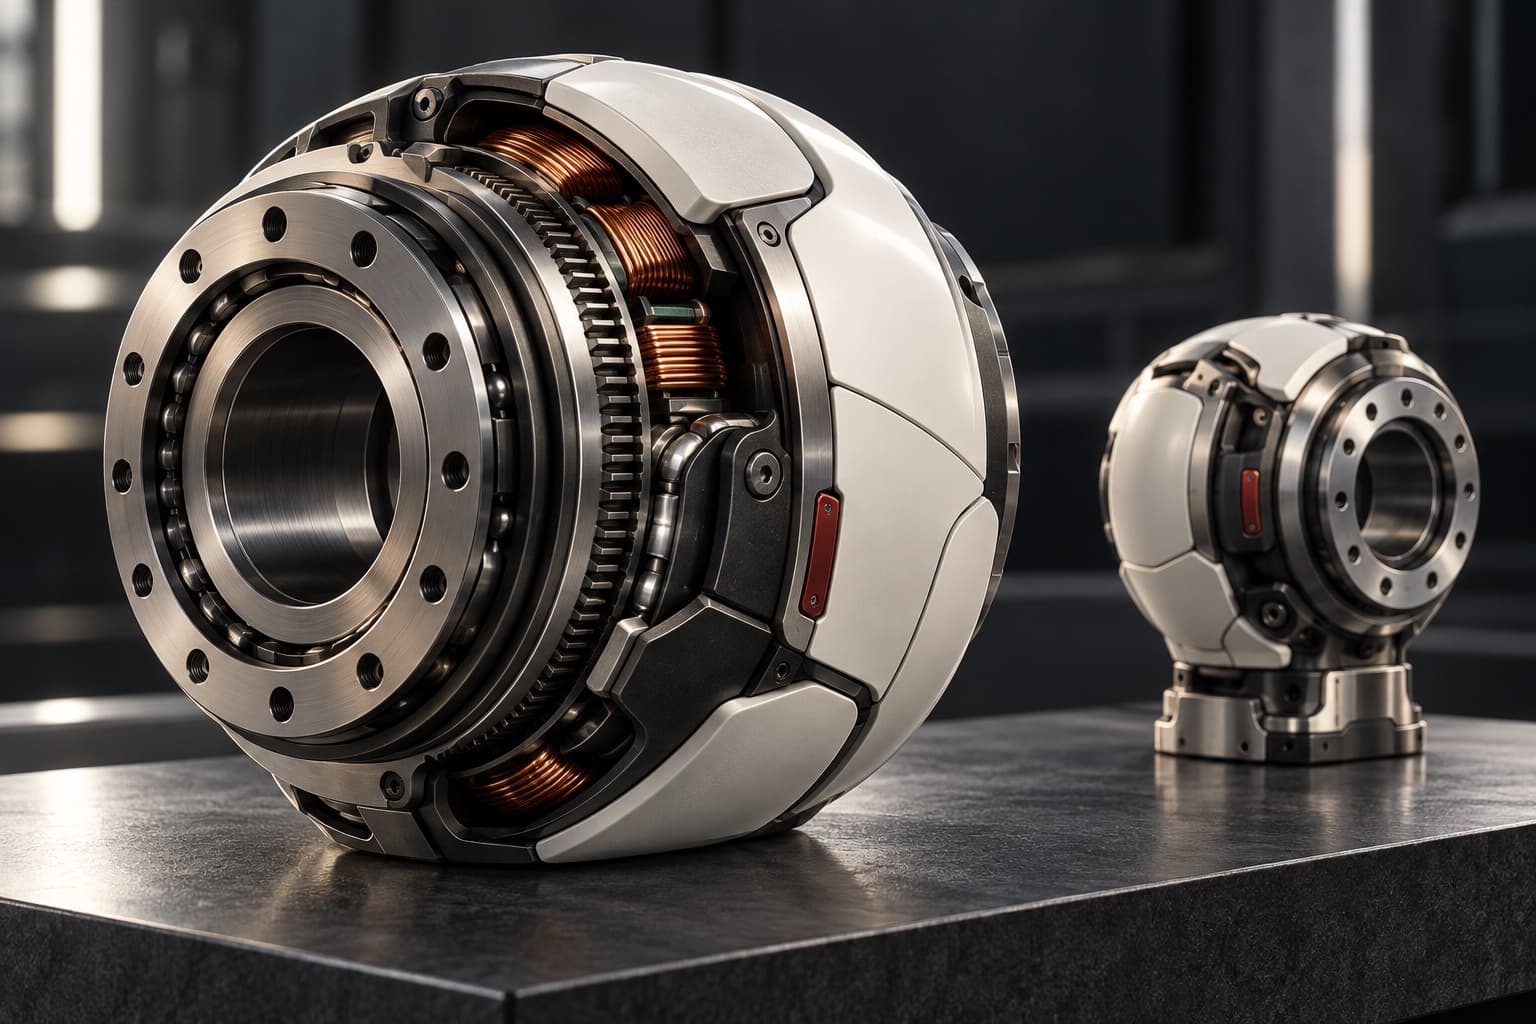
The actuator, as a system.
Components
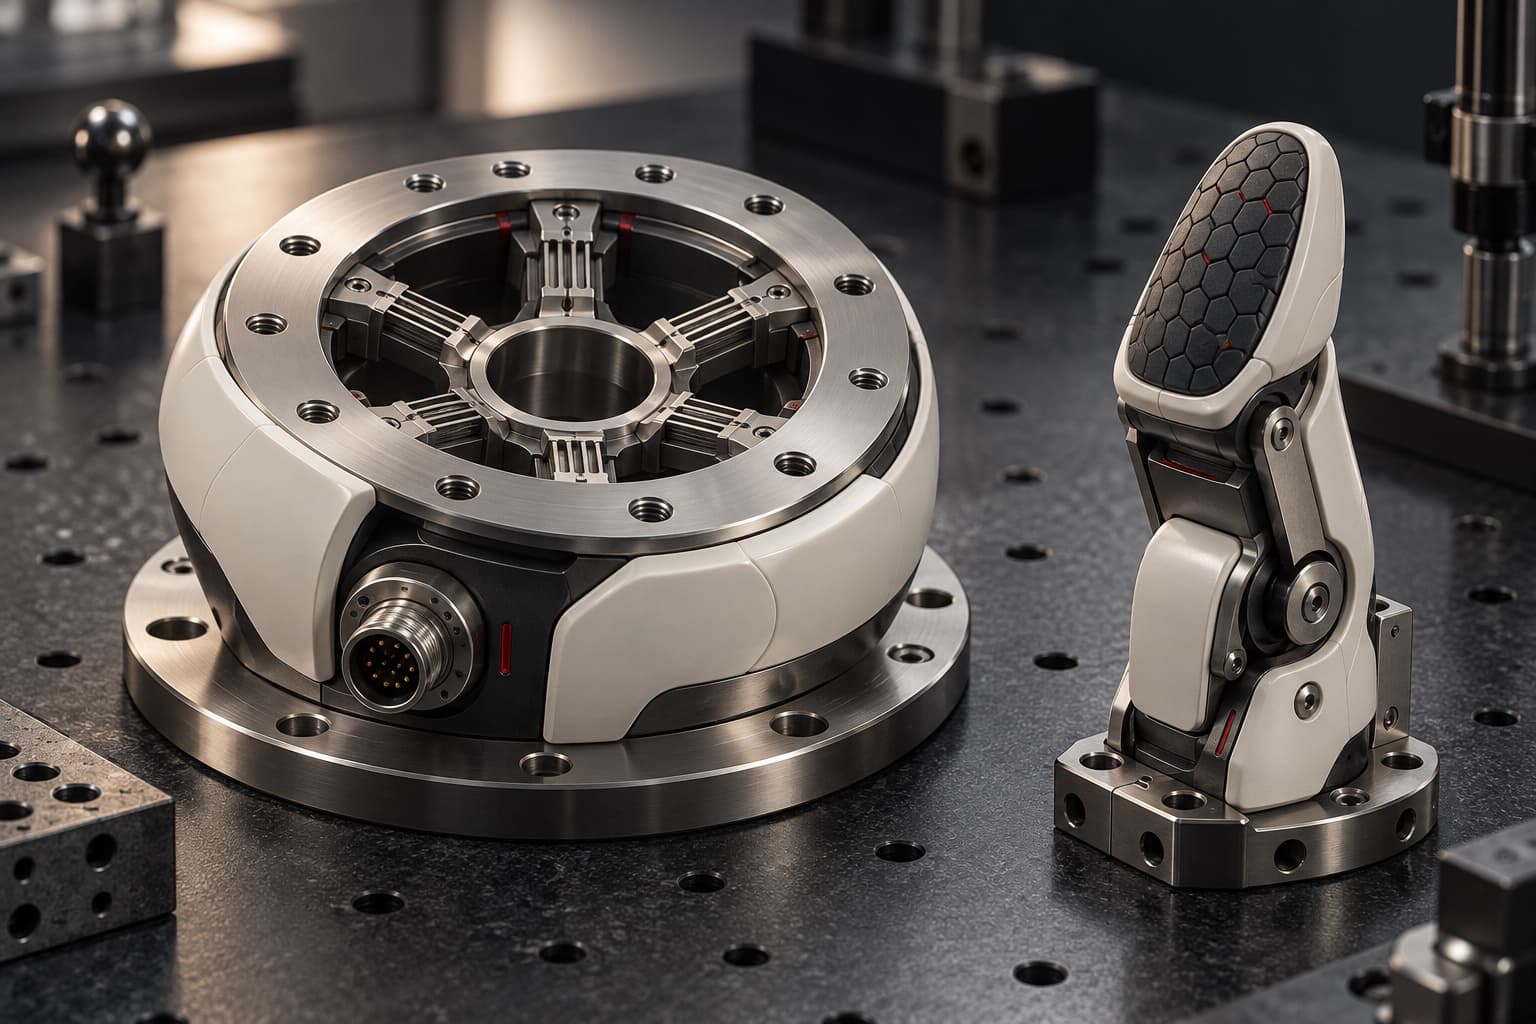
The joint brings the motor, transmission, encoders, and drive electronics into one design.
Torque, back-drivability, force control, and heat depend on the whole actuator. Packaging, sealing, and service are part of that design.
Integration
Motor, transmission, and electronics are one unit.
Feedback
Position and torque feed the control.
Interfaces
Mechanical and electrical connections are defined for the machine.
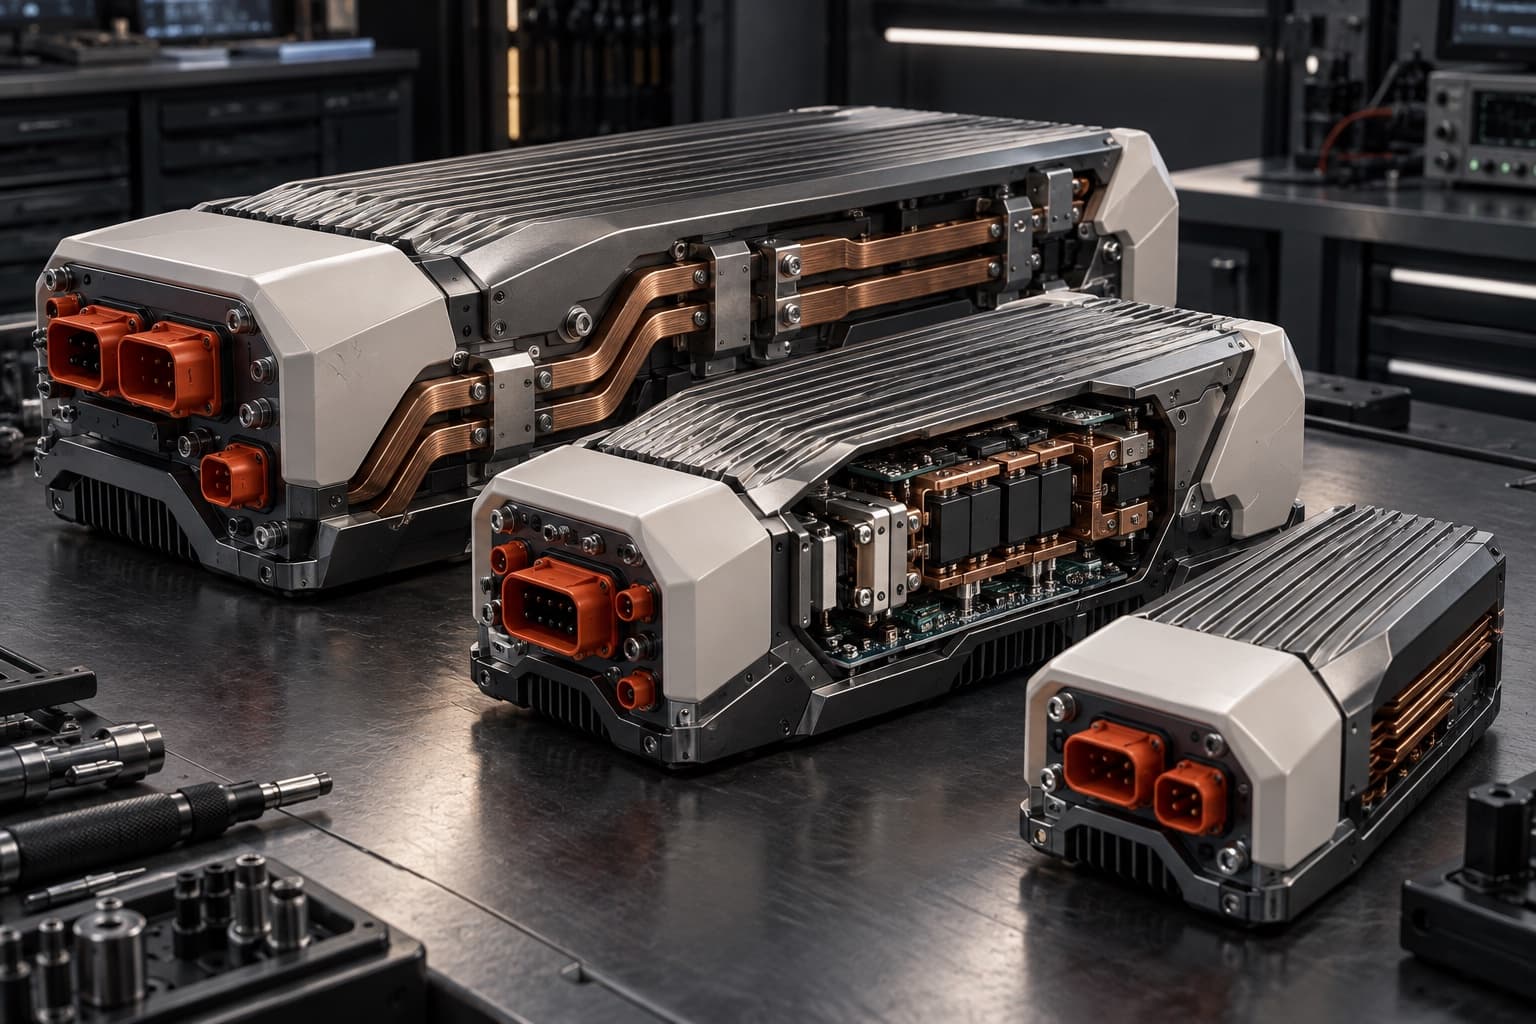
Power, measurement, and control.
Power and sense
Servo drives and sensors give the machine its motion and its picture of contact.
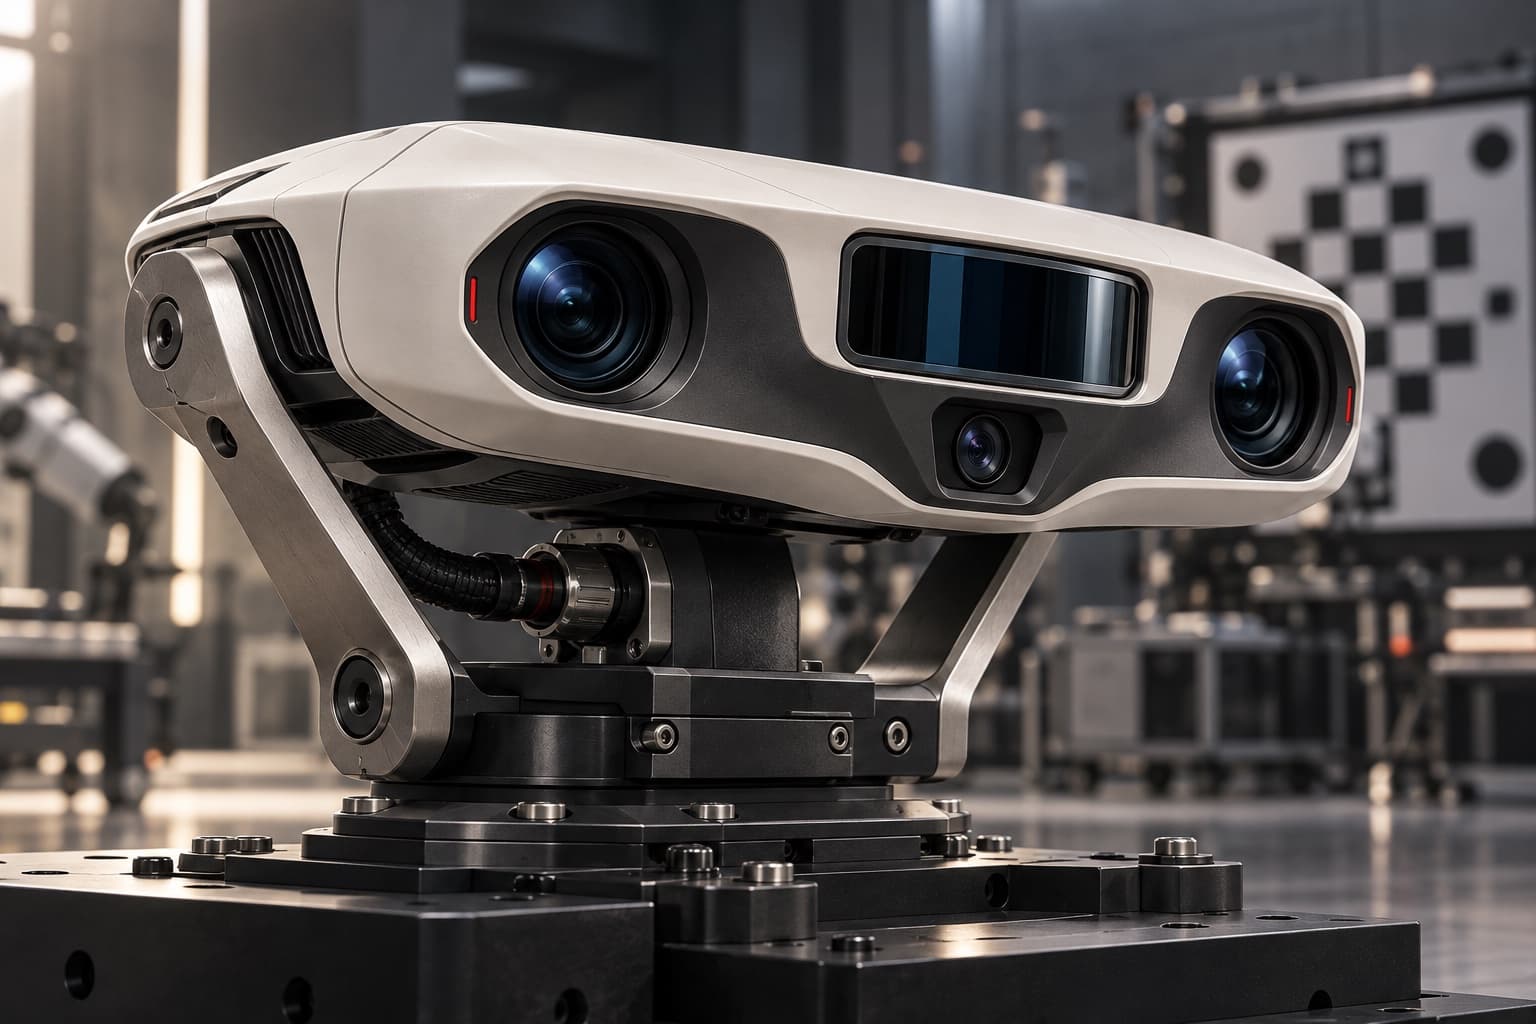
Joint drives, traction inverters, torque sensors, force modules, and tactile sensing are one set. Depth, lidar, and vision share a timing and a coordinate frame, so the machine has one estimate of its state.
Power
Drives are sized for the machine’s operating range.
Contact
Force and torque are tied to the task.
Perception
Timing and coordinate frames are shared across the sensors.
Stack
From the joint up to the machine.
- Operator
- Earthwork
- Motion runtime
- Perception
- Force and torque
- Servo drives
- Integrated actuators
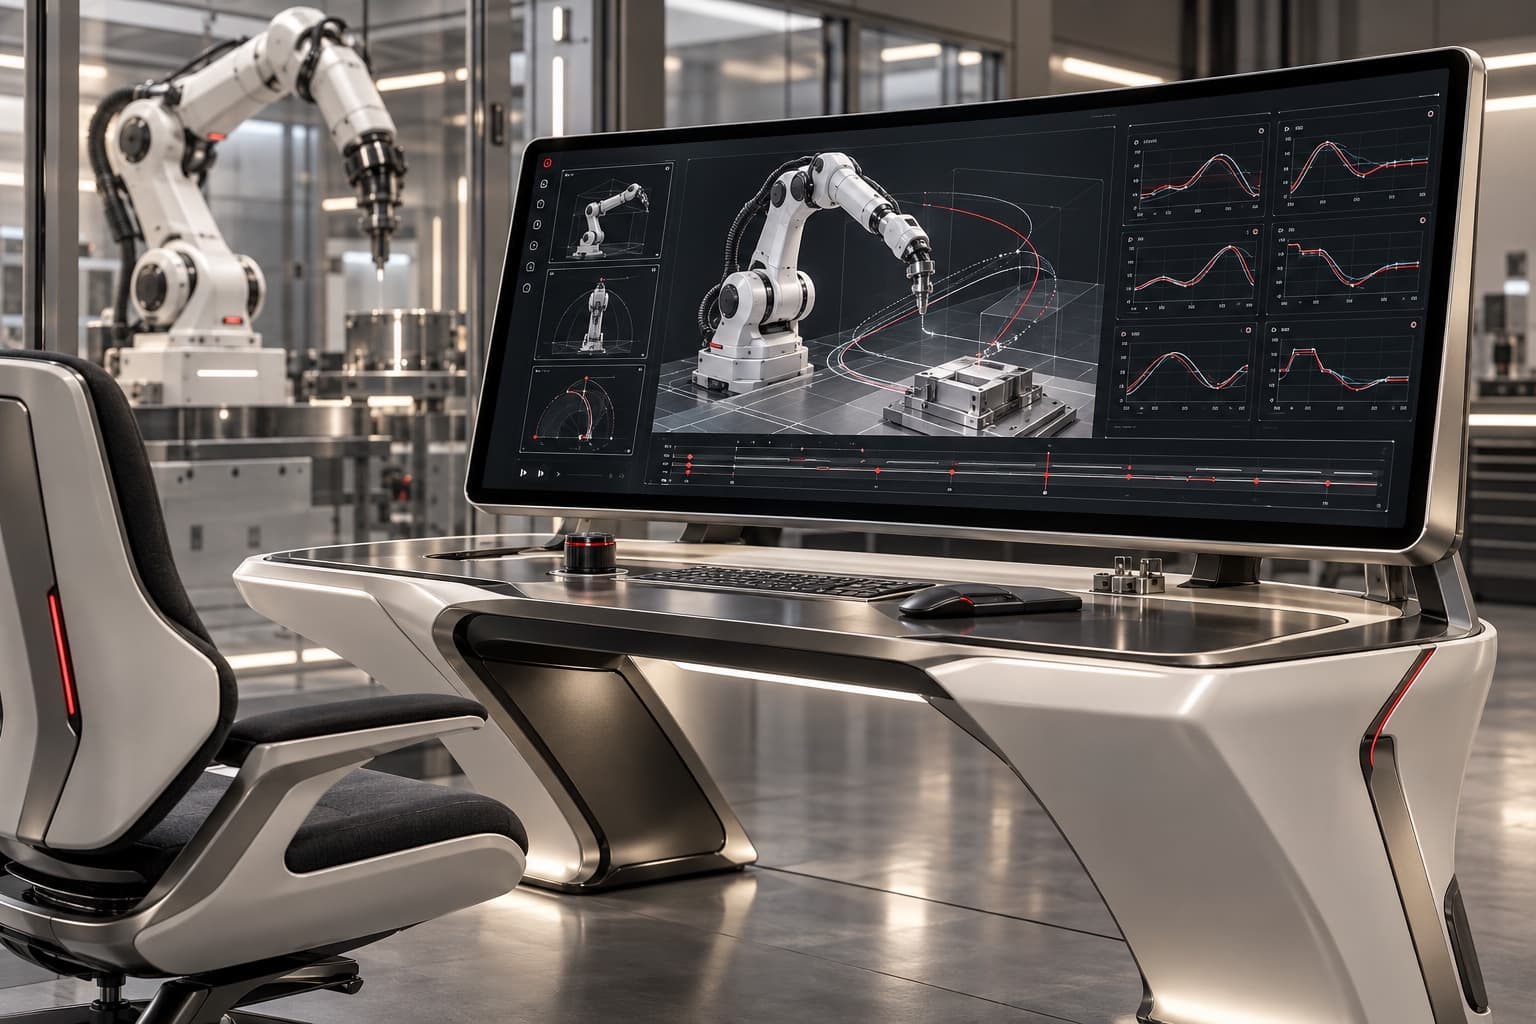
Motion, with limits.
Runtime
The runtime turns a trajectory and a supervisor’s command into local motion.
Control loops, timing, and fault behavior are set at the machine. Stopping, recovery, and operator intervention are part of each application.
Local control
Time-critical functions follow the machine.
Faults
Limits, sensor faults, and a lost link have a defined response.
Integration
The same interfaces serve the component and the machine.
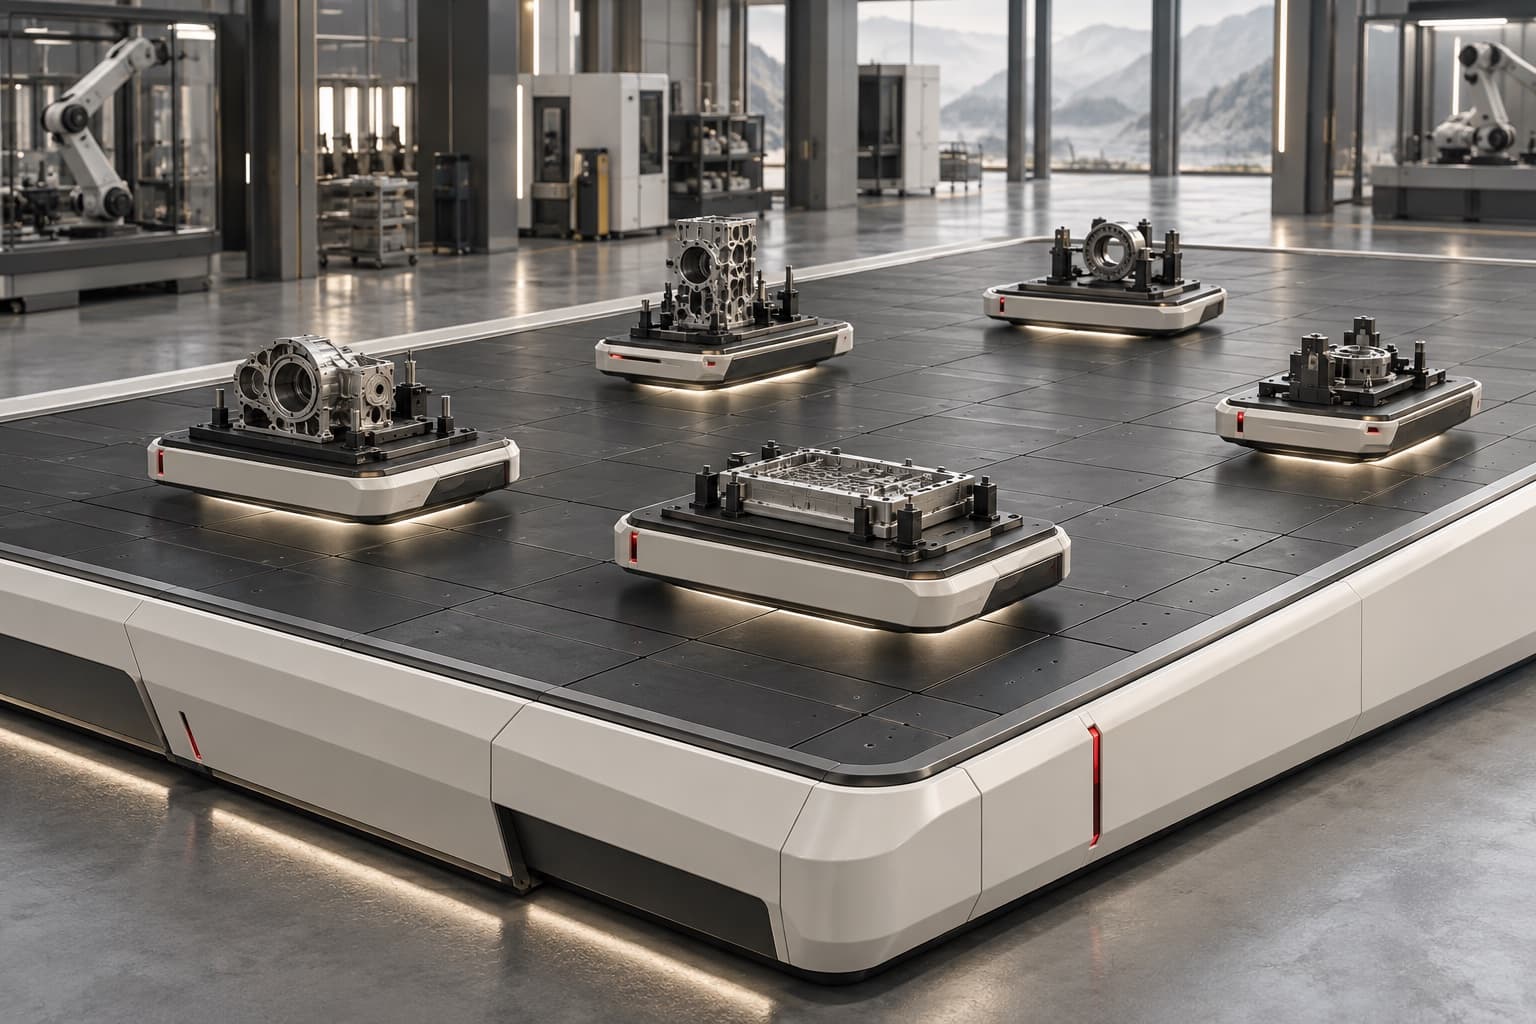
Independent motion on the floor.
Maglev
Planar maglev movers carry and position work independently.
Each mover has its own path. Payload, precision, heat, and control are designed with the process equipment, including how the system responds to a fault.
Routing
Paths follow the production sequence.
Positioning
Accuracy and stability follow the process.
Integration
Equipment, payload, and recovery are in the system.
The component, in the work.
Machines
Operator, Earthwork, Steward, and Continuum put the same motion and control to different work.
The machines cover manipulation, heavy site work, environmental tasks, and continuous handling. Each one sets its loads, its workspace, its maintenance, and how a person works with it.
Operator
Manipulation, with a person in supervision.
Earthwork and Steward
Equipment for heavy work and for the site.
Continuum
Coordinated handling across a continuous process.
Joints, senses, and machines that do the work.
Actuation, perception, and control, as parts or as a machine.
Actuation & sensing
Perception & control
Machines & mobility
Maglev movers
Conveyance
Independent carriers on a planar track.
Operator
Machine
A manipulation machine, with a person in supervision.
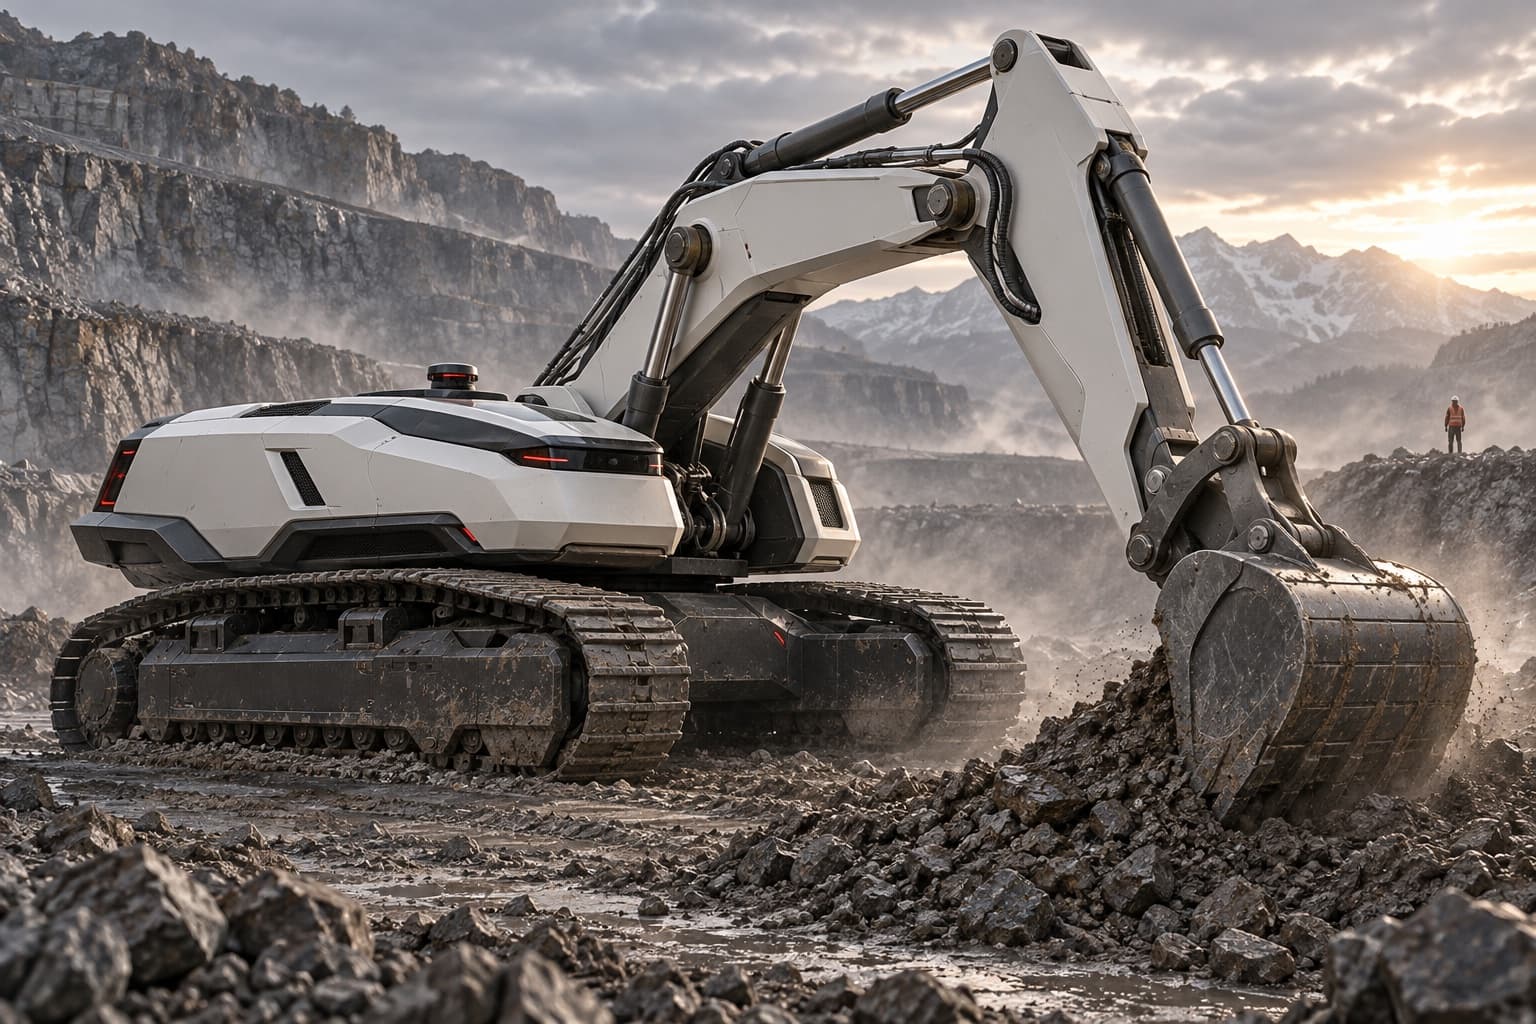
Earthwork
Machine
A machine for heavy work on a site.
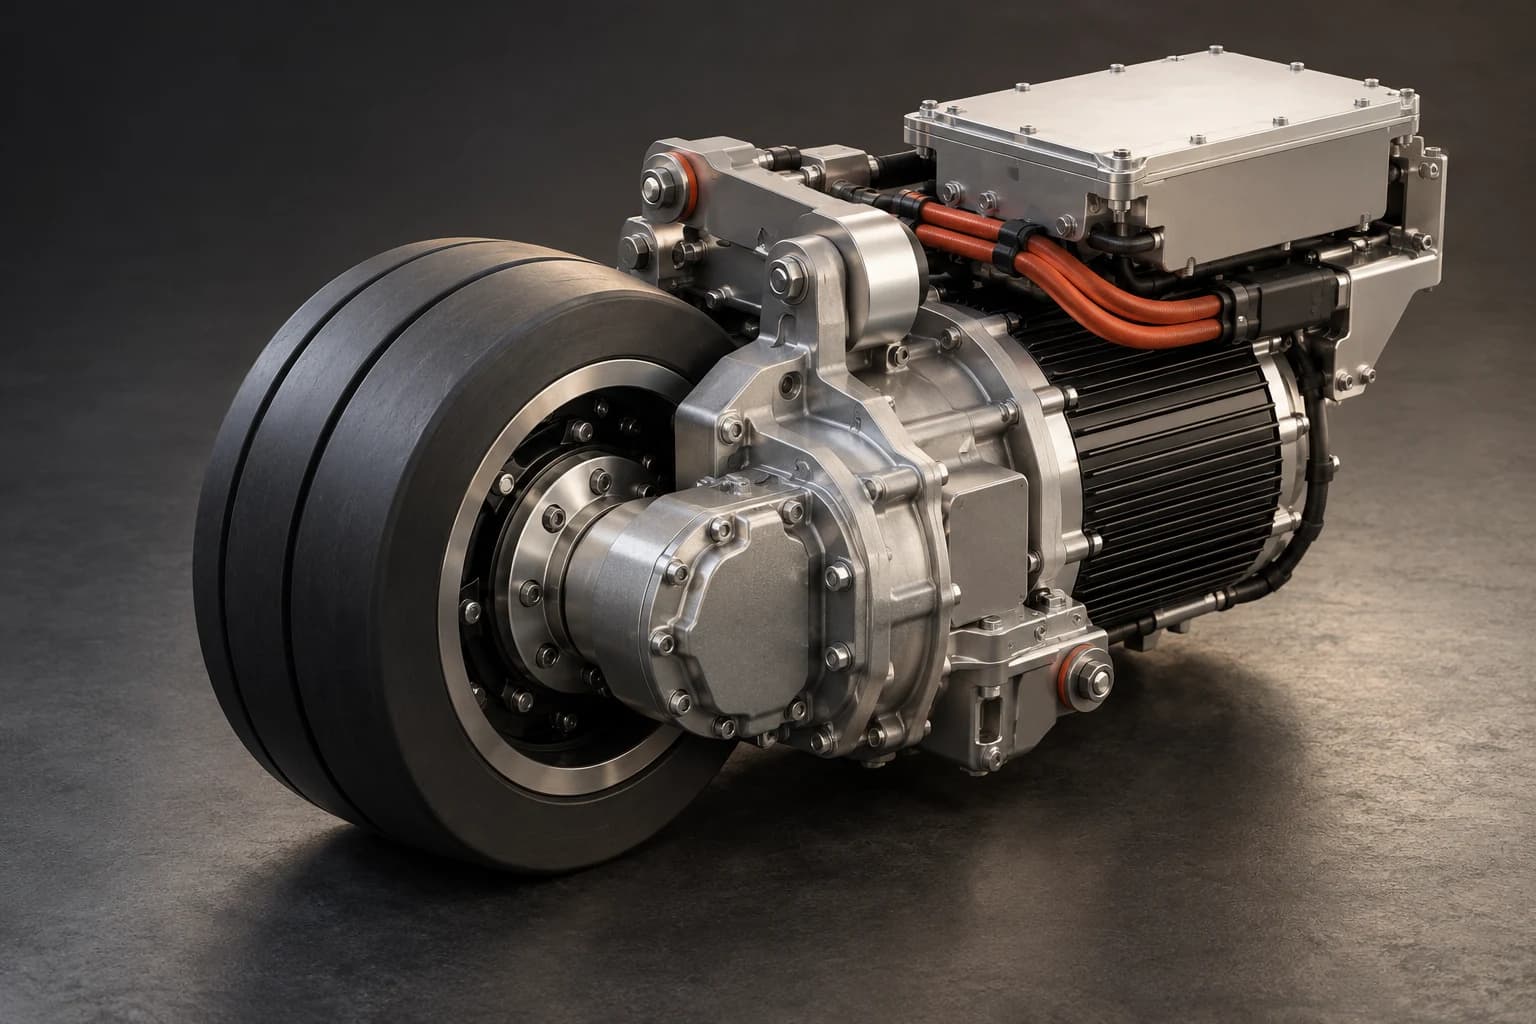
Industrial Mobility
Robotics programs
Electric traction for the machines that move the work.
Drive Module
Industrial ground powertrain
Electric traction for the machines that move the work.
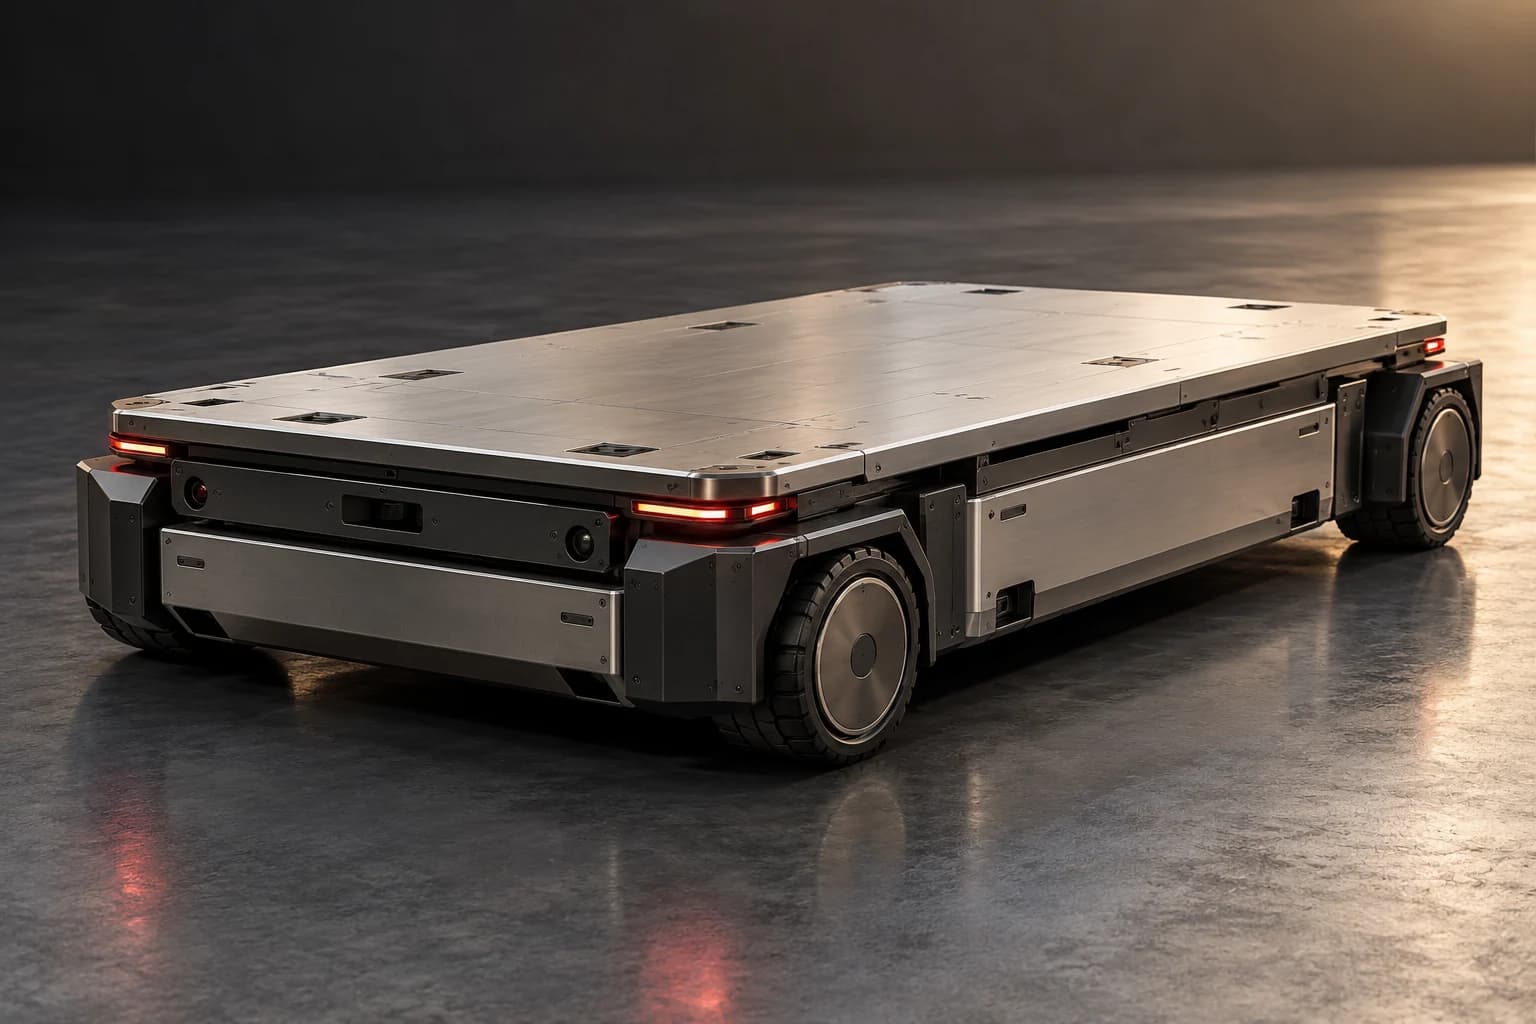
Cargo Base
Industrial ground powertrain
A ground platform for moving goods through the facility.
Motion components
Integrated actuators, servo drives and force-and-torque sensing are evaluated as a coordinated electrical and mechanical system.
Perception and control
Sensor timing, machine geometry, and local control support predictable work in the physical environment.
Machine programs
Operator, Earthwork, Steward, and Continuum put the same components to different tasks and environments.
Build the frontier
with us.
Share the objective, the requirements, and the business you want to reach. Project and partnership enquiries all come through the same form.
Discuss a Project